Bat-Inspired UAS for Mapping and Navigation
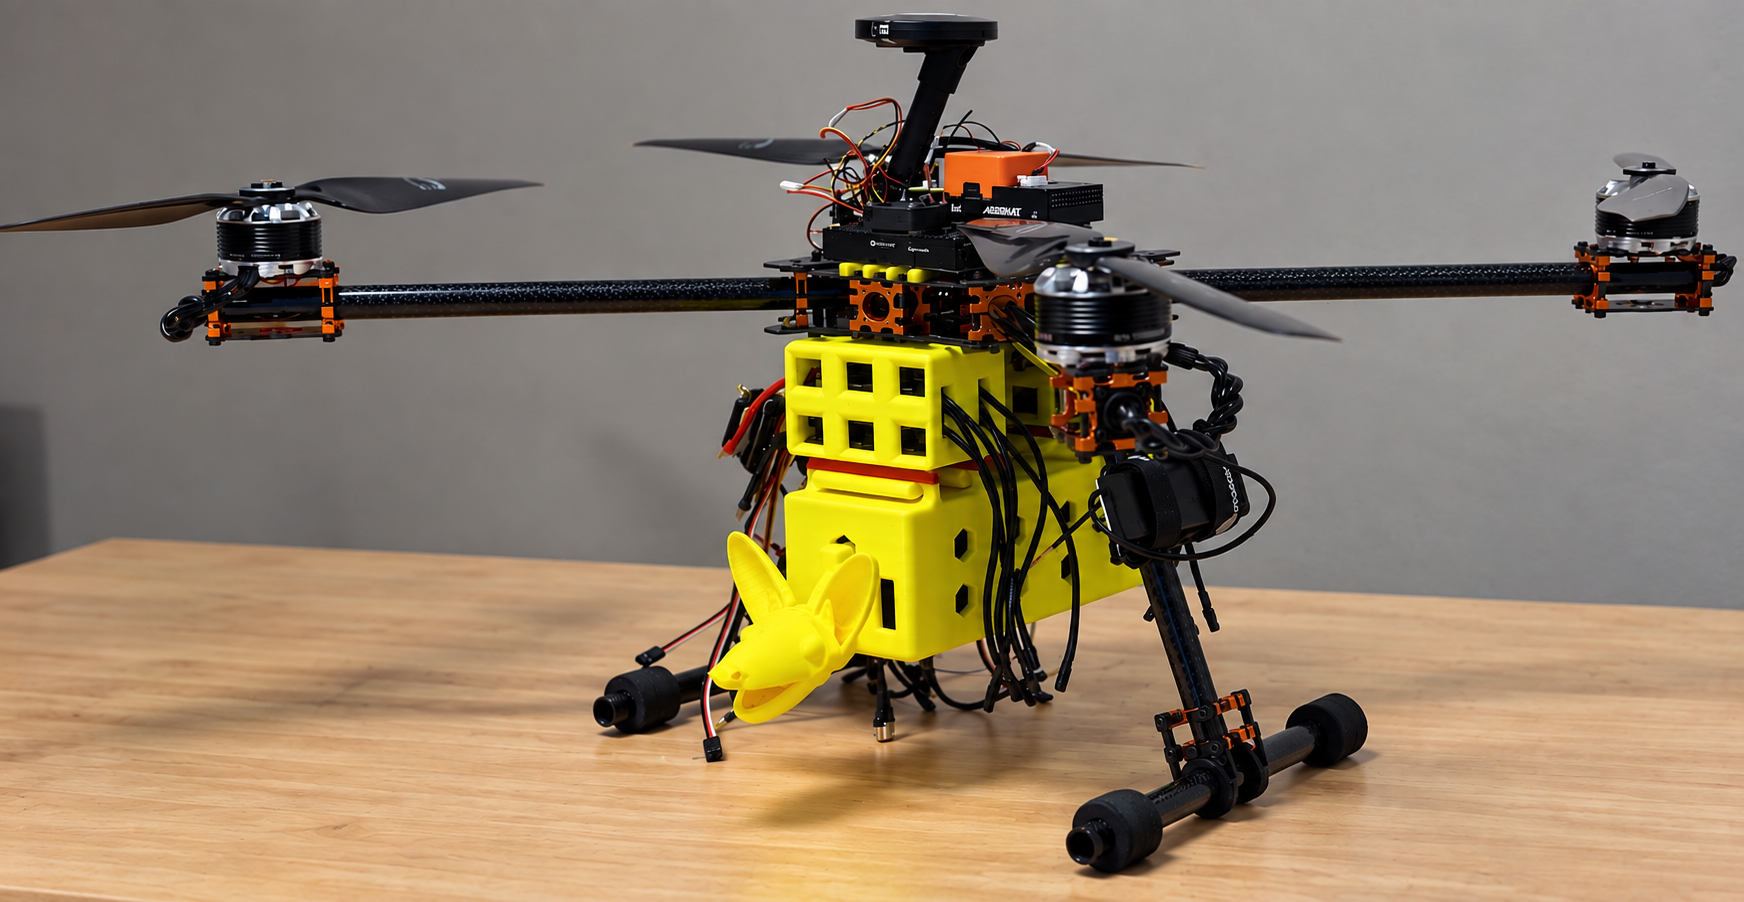
Designed and prototyped custom components for a bat-inspired unmanned aerial system designed around an echolocation-based navigation and mapping concept.
A collection of my work in robotics projects and engineering work
Designed and prototyped custom components for a bat-inspired unmanned aerial system designed around an echolocation-based navigation and mapping concept.
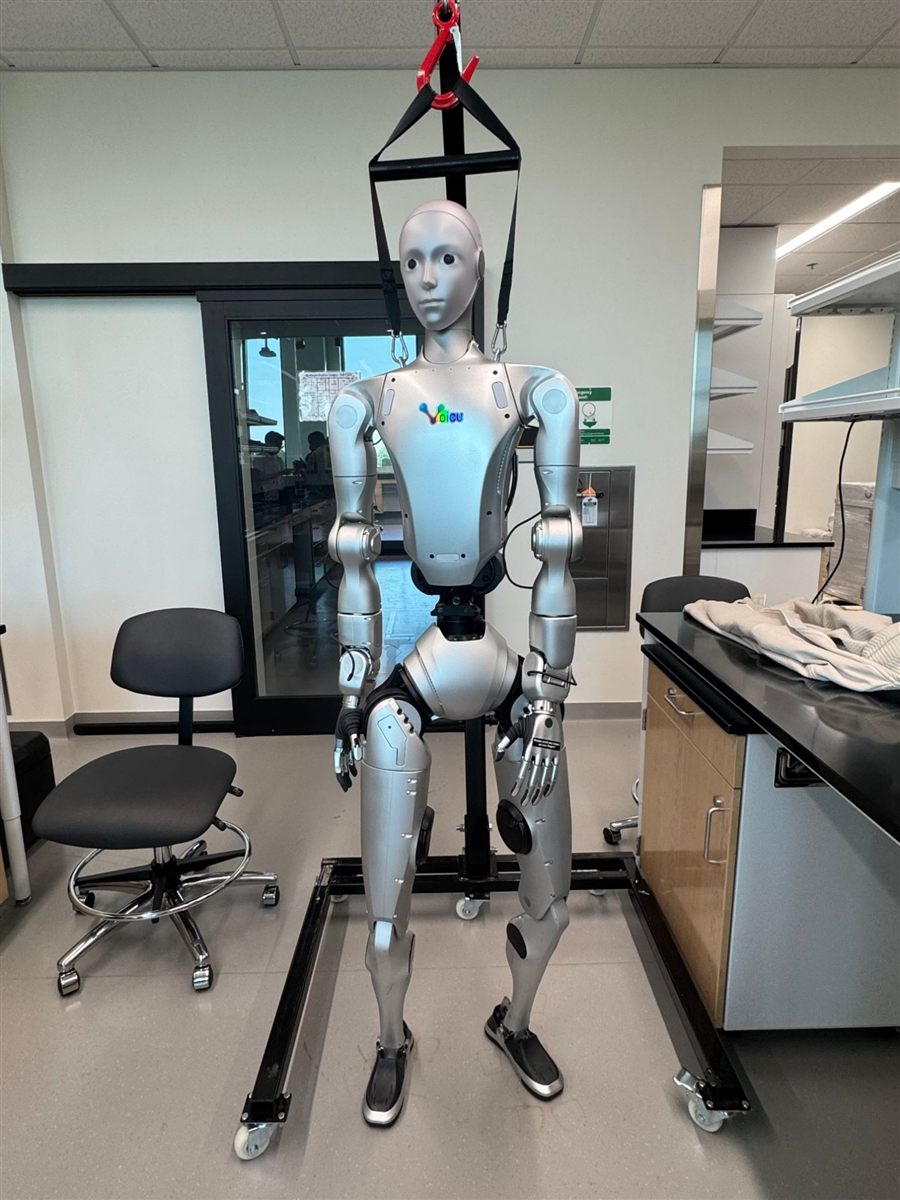
Developing an AI-powered laboratory assistant on the Unitree H2 humanoid robot that combines information management with perception, navigation, and manipulation to support daily lab activities.
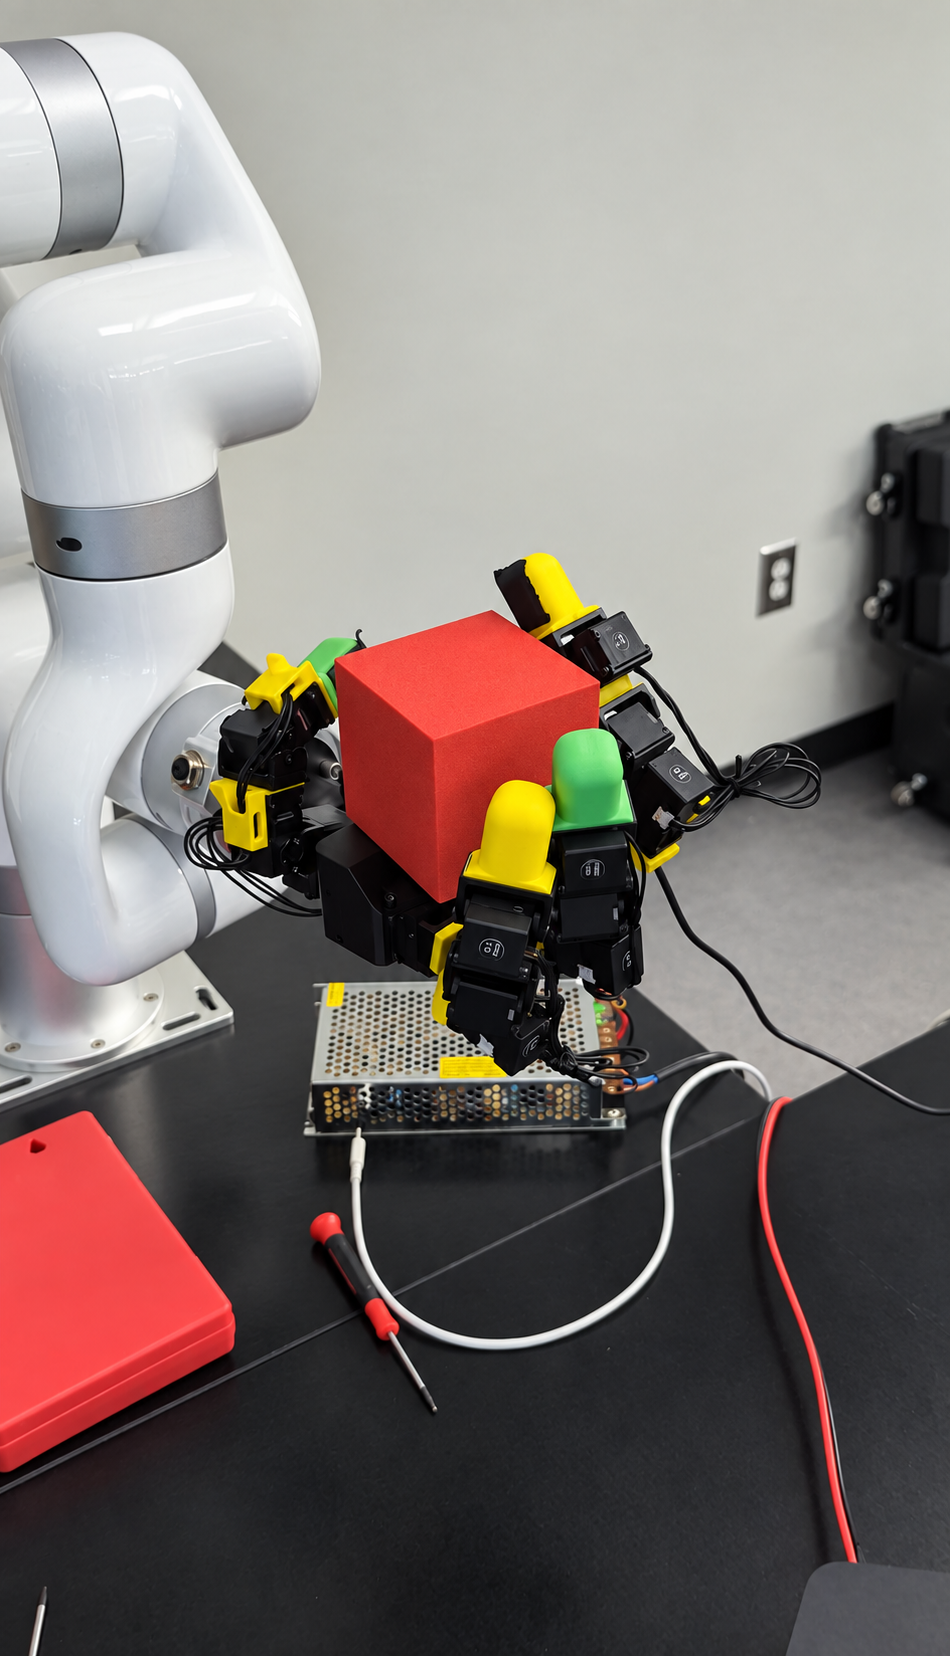
Assembled and calibrated the LEAP Hand and deployed a sim-to-real policy for in-hand cube rotation, with ongoing work on OptiTrack-based cube reorientation.
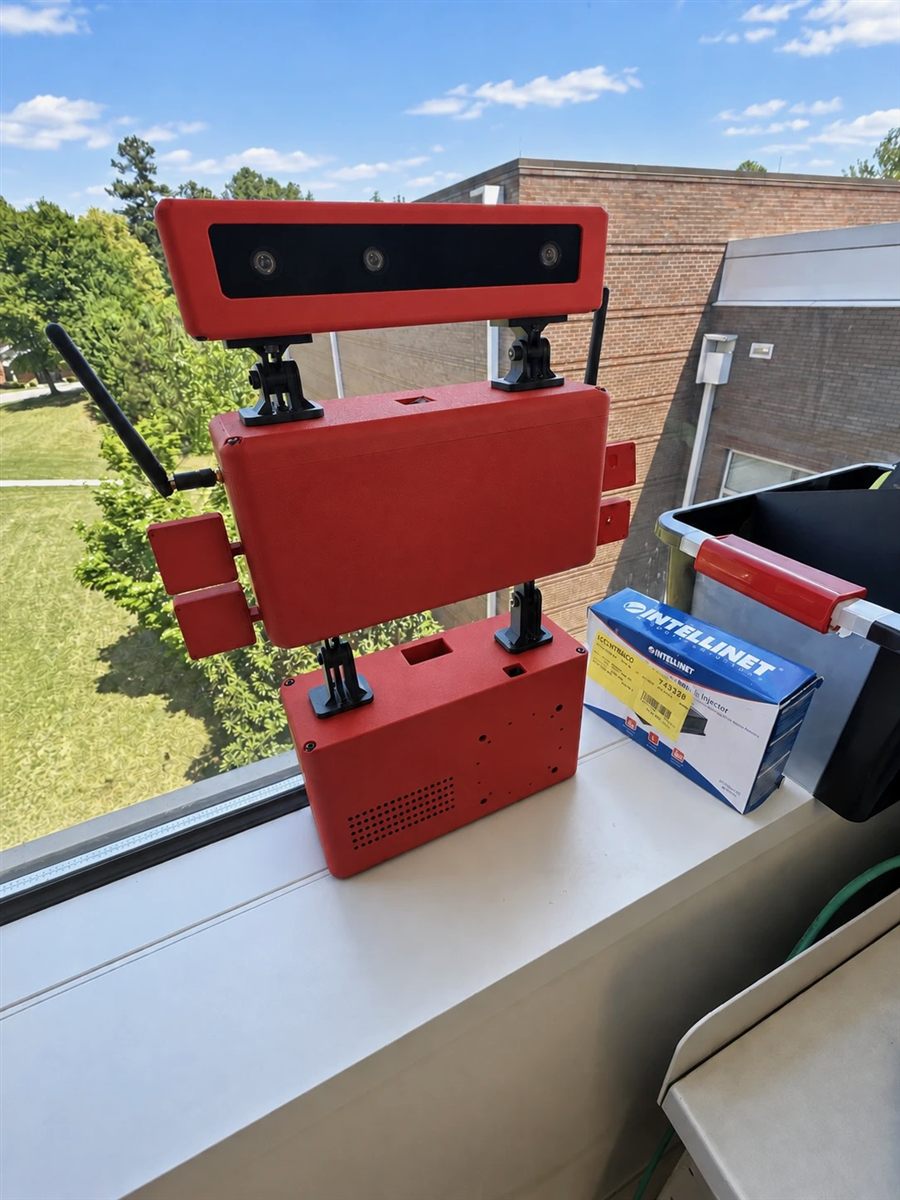
Designed and fabricated modular sensing unit enclosures for the PLOT house at Kennesaw State University, with interchangeable camera configurations and a mounting attachment for the Unitree R1 humanoid robot.