LEAP Hand for In-Hand Manipulation
Overview
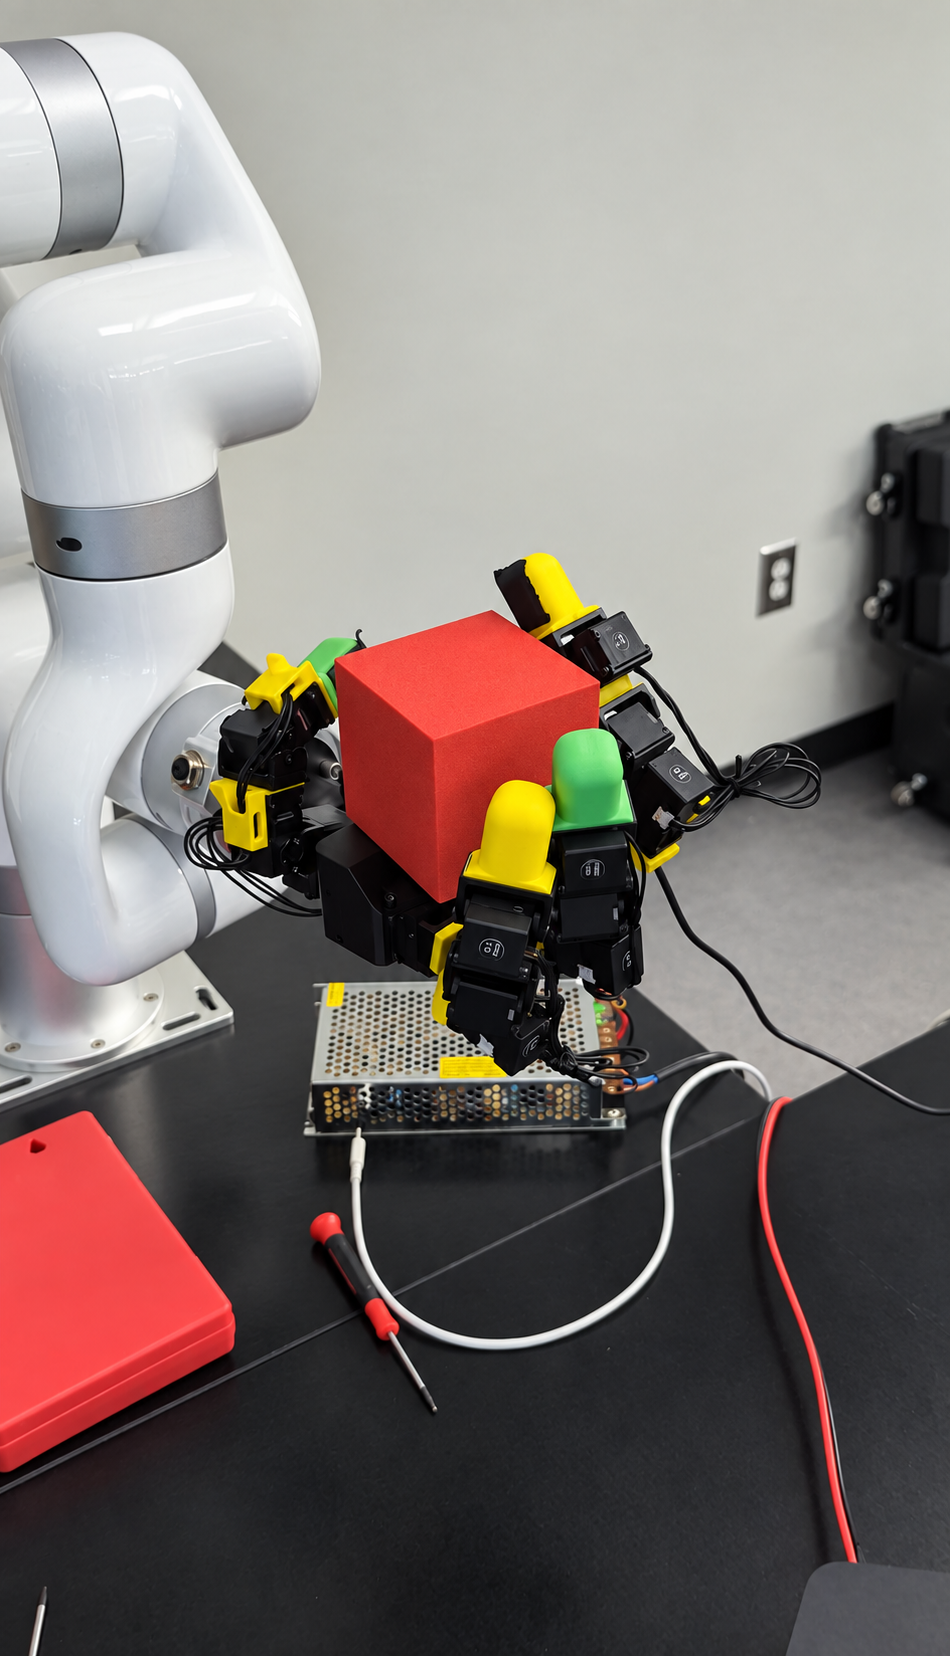
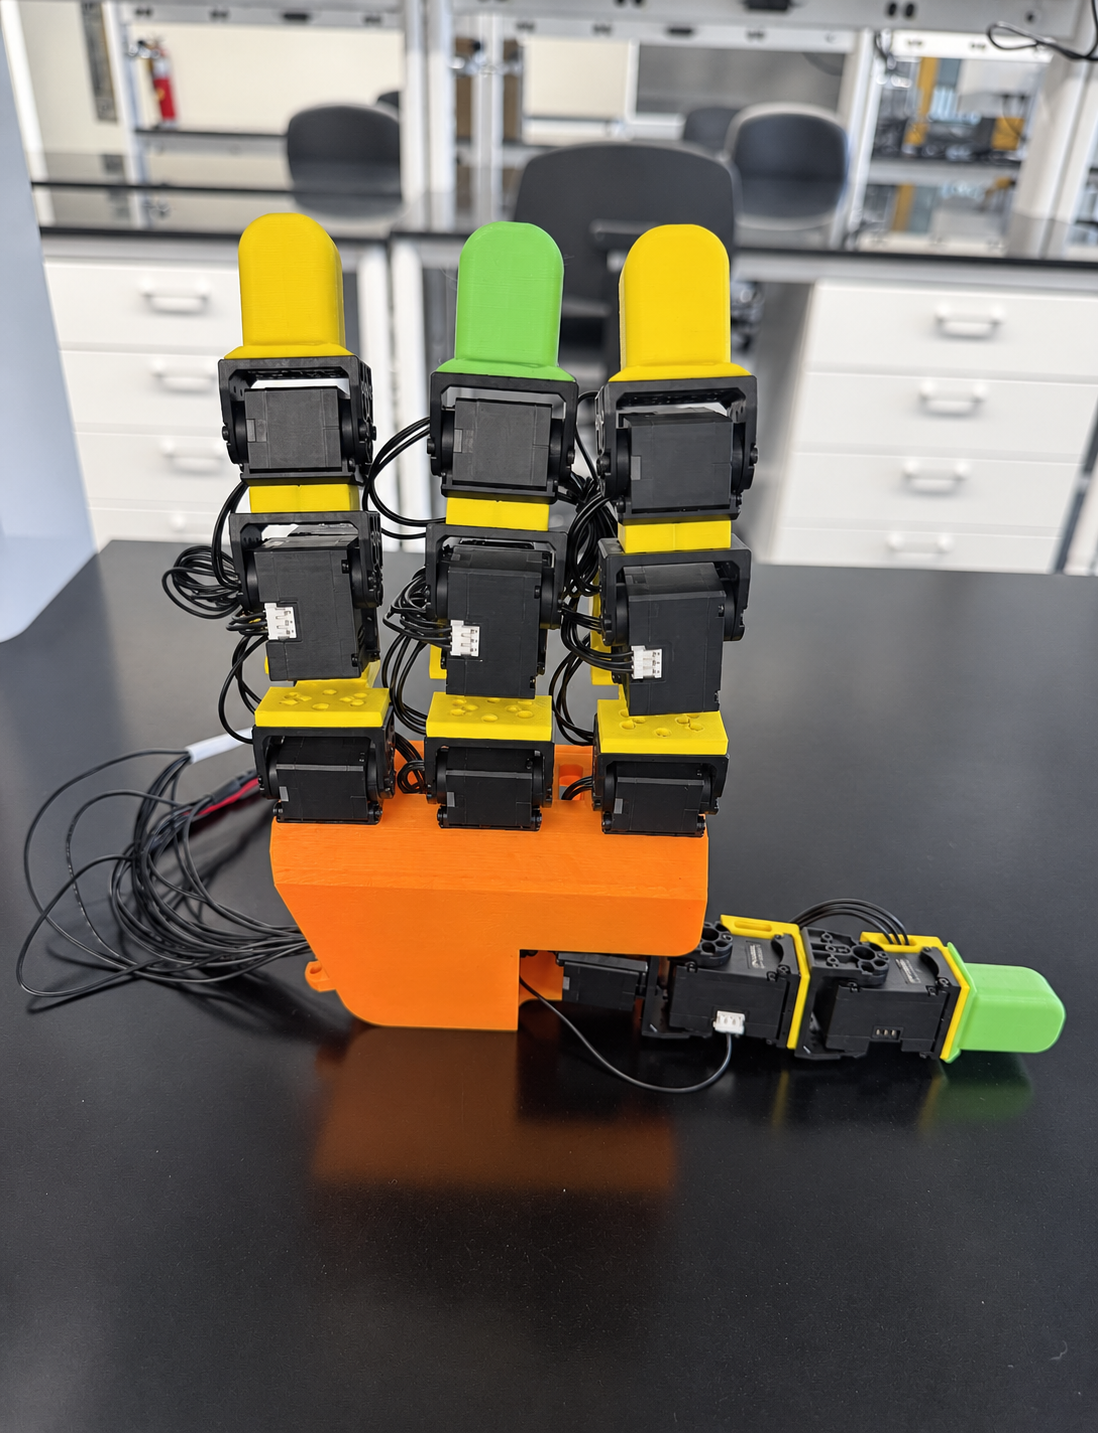
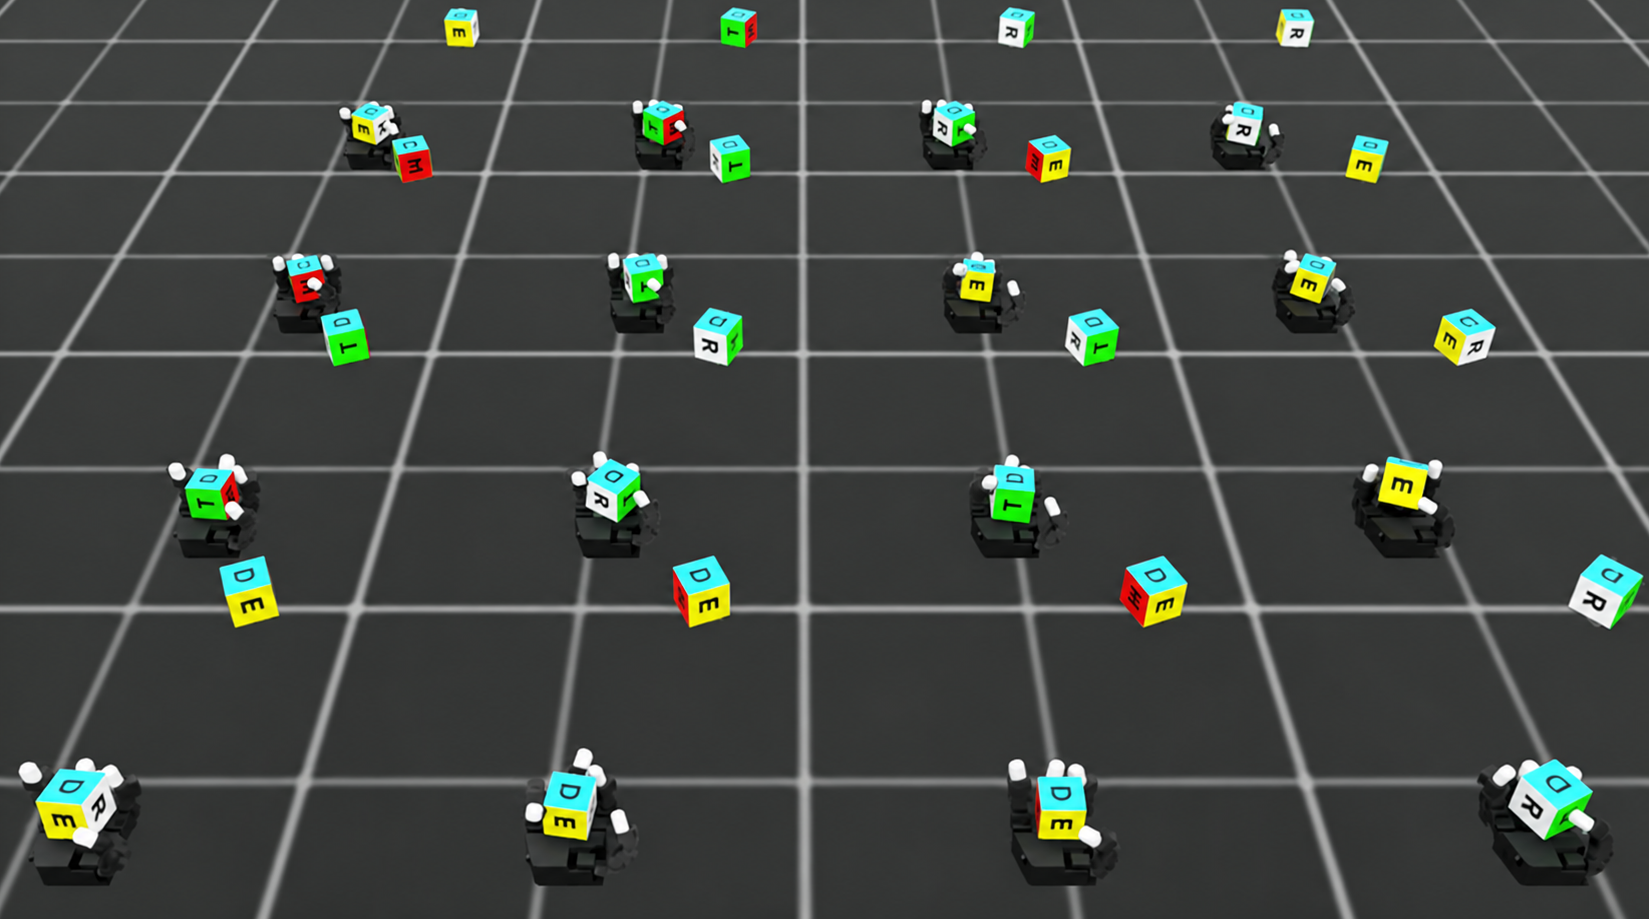
This project focuses on dexterous manipulation with the open-source LEAP Hand developed at Carnegie Mellon University. The hand was assembled and calibrated, and a sim-to-real policy was integrated and deployed onto the physical hardware to achieve in-hand cube rotation. Ongoing work aims to reproduce the cube reorientation task from the MuJoCo Playground paper, using a four-camera OptiTrack setup for real-time pose tracking.
Implementation
- 3D printed and assembled the LEAP Hand, including motor setup and joint calibration.
- Integrated and deployed a sim-to-real manipulation policy onto the physical hardware.
- Tuned PID gains and corrected motor offsets to achieve in-hand cube rotation.
Current Work
- Developing a four-camera OptiTrack setup to track the cube’s pose during manipulation.
- Working toward reorienting the cube to a generated target one face turn away, following the task presented in the MuJoCo Playground paper.
Project Gallery
Camera setup and reorientation results will be added as that work progresses.
Acknowledgements
This project is being developed in collaboration with Edward Osun and Angel Campos under the guidance of Dr. Lingfeng Tao at Kennesaw State University.